|
My research interests are in studying and improving the physical understanding of vision diffusion models. I also work on applying frontier vision techniques and physics-informed neural networks to scientific applications in medicine and battery management. I am honored to be awarded the 2025 Amazon Fellowship and the 2026 UCLA Jonsson Comprehensive Cancer Center Fellowship. I attended UC Berkeley for my undergrad where I was fortunate to work with Prof. Ren Ng and Prof. Avideh Zakhor.
Email / Google Scholar / CV / Github
I am on the job market for industry/postdoc research roles starting Spring 2027, focused on video-based world models, AI for Science, and world models for robotics. |
|
|
|
|
|
Representative/Recent papers are highlighted |
|

|
Rishi Upadhyay, Howard Zhang, Jim Solomon, Ayush Agrawal, Yunhao Ba, Alex Wong, Celso De Melo, Achuta Kadambi arXiv, 2026 PDF / project page / dataset We evaluate how closely world models align with the physical world using a set of synthetic videos which test different physics concepts. |
|
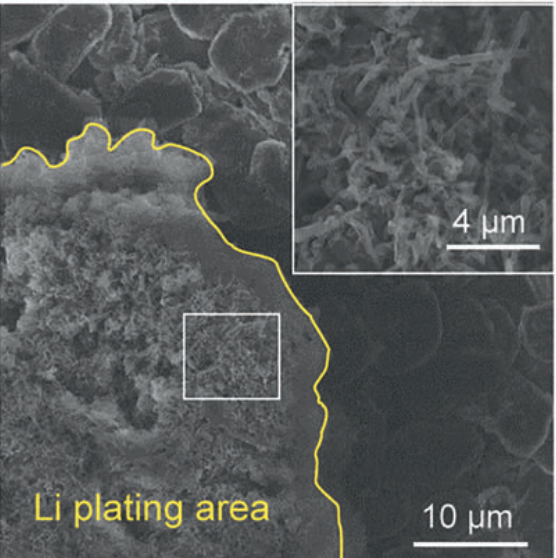
Jiayi Yu*, Aki Takahashi*, Min-Ho Kim*, Rishi Upadhyay*, Howard Zhang*, Tian-Yu Wang*, Huayang Zhu, Robert Kee, Tyrone Vincent, Bo Liu, Xintong Yuan, Thomas Hymel, Kaiyan Liang, Keyue Liang, Haoyang Wu, Dingyi Zhao, Jung Tae Kim, Achuta Kadambi, Yuzhang Li Nature Communications, 2026 We train a machine learning model to estimate internal electrode potentials from standard battery operating data, preventing lithium plating and enabling safer fast-charging. Personally led the development of ML model from data to deployment. |
|
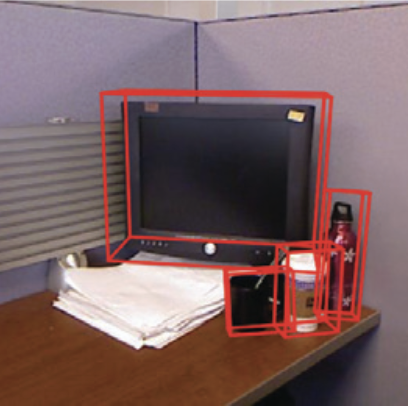
Changwoo Jeon, Rishi Upadhyay, Achuta Kadambi, ECCV, 2026 PDF / project page / code Predicting pixel-aligned 3D bounding boxes from a single image without requiring camera intrinsics by using dense corner heatmaps and depth maps. |

|
Rishi Upadhyay, Pascal Paysan, Supratik Bose, William Delery, Yunzheng Zhu, William Hsu, Daniel Low, Stefan Schieb, Achuta Kadambi, Ricky R. Savjani, Under Review, 2025 PDF / We develop VAE and Diffusion based generative models that model breathing motion in lung CT scans for better radiation targeting. |

|
Haolin Xiong*, Sairisheek Muttukuru*, Rishi Upadhyay, Pradyumna Chari, Achuta Kadambi 3DV, 2025 PDF / project page We integrate 3D Gaussian Splatting with depth regularization and diffusion priors to enable 360° novel view synthesis from just 12 views. |

|
Blake Gella*, Howard Zhang*, Rishi Upadhyay, Tiffany Chang, Matt Waliman, Yunhao Ba, Alex Wong, Achuta Kadambi arXiv, 2023 PDF / project page We introduce the first paired semantic segmentation dataset in adverse conditions and show that techniques that leverage this paired nature can significantly improve performance. |

|
Rishi Upadhyay, Howard Zhang, Yunhao Ba, Ethan Yang, Blake Gella, Sicheng Jiang, Alex Wong, Achuta Kadambi ACM TOG, SIGGRAPH Asia, 2023 PDF / Code / Project Page We propose a loss function for latent diffusion models that improves the perspective accuracy of generated images, allowing us to create synthetic data that helps improve SOTA monocular depth estimation models. |

|
Vimal Prabhu Pandiyan, Sierra Schleufer, Emily Slezak, James Fong, Rishi Upadhyay, Austin Roorda, Ren Ng, Ramkumar Sabesan Biomed. Opt. Express, 2022 We characterize cone classification by ORG. Personally worked on the Retina Map Alignment Tool. |

|
Reshma Singh, Samuel Fernandes, Anand Krishnan Prakash, Paul Mathew, Jessica Granderson, Colman Snaith, Rahul Pusapati, Prakash Jadhav, Avideh Zakhor, Rishi Upadhyay, Ozgur Gonen, Harry Bergmann Technical Report, Lawrence Berkeley National Labratory, 2022 We create an automated tool to estimate building energy efficiency through drone and thermal imaging. |

|
Revekka Kostoeva, Rishi Upadhyay, Yersultan Sapar, Avideh Zakhor ISPRS, 2019 We use a smartphone, AR techniques, and object classifiers to create a system to automatically detect and map objects of interest in a 3D scene. |
|
Credit to Jon Barron for the website template. |